Concepts
Core OctoMY™ concepts
Concepts
Core concepts that underpin OctoMY™'s design. Understanding these helps you make better decisions when building with OctoMY™.
Did You Know?
Many of OctoMY™'s concepts - like Plans, Couriers, and Trust Levels - were named to be intuitive even without documentation. A "Plan" is exactly what it sounds like: a script describing what the robot should do. A "Courier" delivers messages. Trust levels work like human trust relationships.
Topics
Networking and trust
| Topic | Description |
|---|---|
| Communication system | Secure peer-to-peer networking |
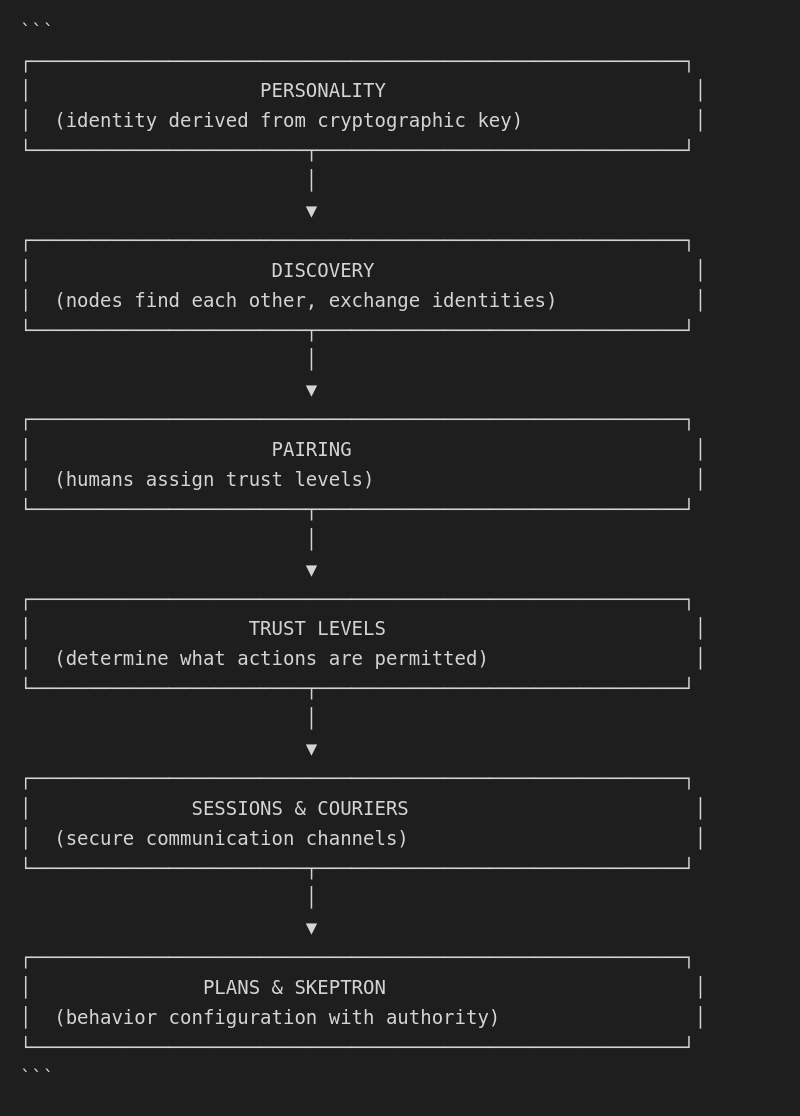
| Discovery and pairing | How nodes find each other and establish trust |
| Couriers and sessions | Secure channels and typed message handlers |
| Trust levels | Graduated trust from Block (0) to Depend (5) |
Identity and behaviour
| Topic | Description |
|---|---|
| Plans and skeptron | Robot behavior and authority management |
| Personality | Unique identity from cryptographic keys |
| Sentient identity | Cryptographic human identity for conscious entities |
| Hive | The encrypted storage classes that hold identity, data, and per-node state |
| Identity switching | Mid-session sentient and node switching, the six-phase cascade |
Hardware control
| Topic | Description |
|---|---|
| Fixo overview | What Fixo is — board, servos, sensors, and the firmware compiler |
| Why Fixo | Why a single static-config controller path |
| How Fixo firmware is generated and compiled | LLVM toolchain, BLAKE3 caching, AVR + native pipelines |
| Stanzas, sets, and conflict resolution | Why mutual exclusion is a first-class concept |
| The Fixo prefix and the Fixo / Fluxo split | Naming conventions and history |
Why these concepts matter
Understanding these concepts helps you:
- Make better architectural decisions when extending OctoMY™
- Troubleshoot problems effectively by understanding the underlying mechanisms
- Design appropriate trust relationships for your use case
- Create compatible Plans that work correctly with the authority model
Concept relationships