hardware
Articles tagged hardware in octomy
-
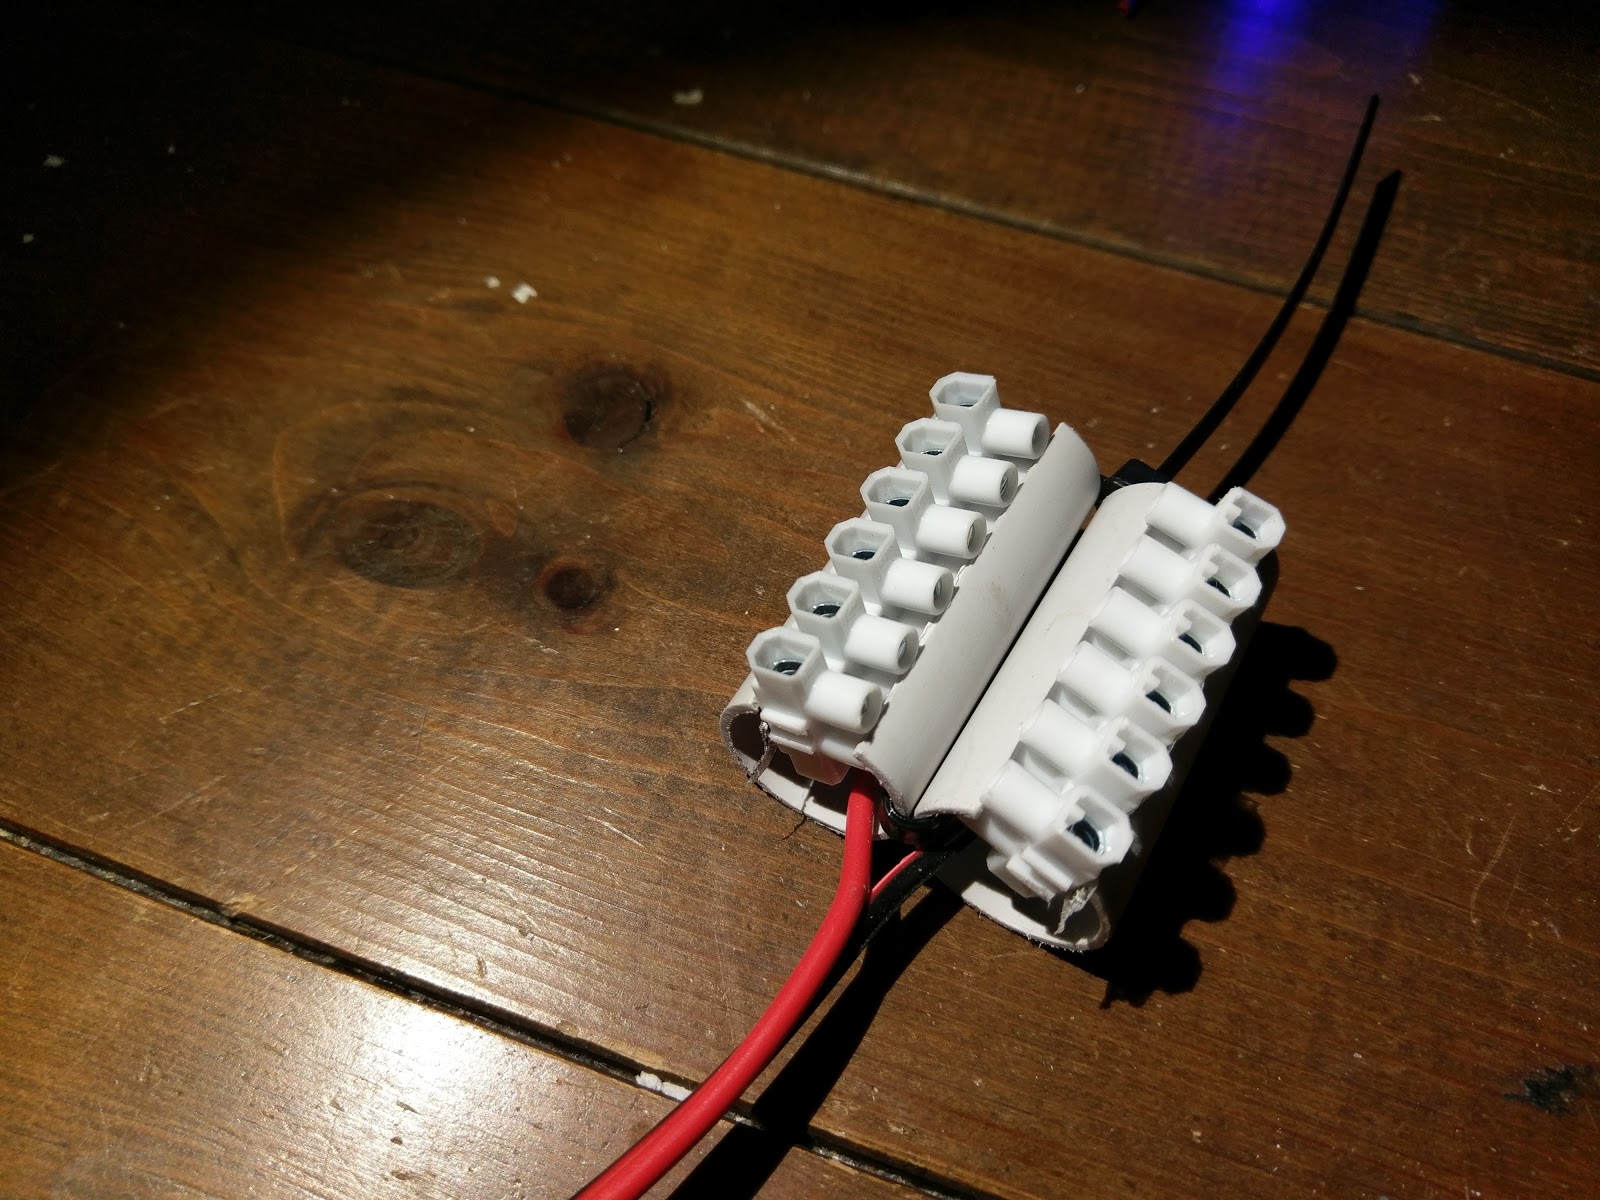
Wheeled rig update
10 January 2017Just a quick update on the wheeled rig. Electronics are starting to come together. Power bar created. Main power bar was created and connected to battery…
-
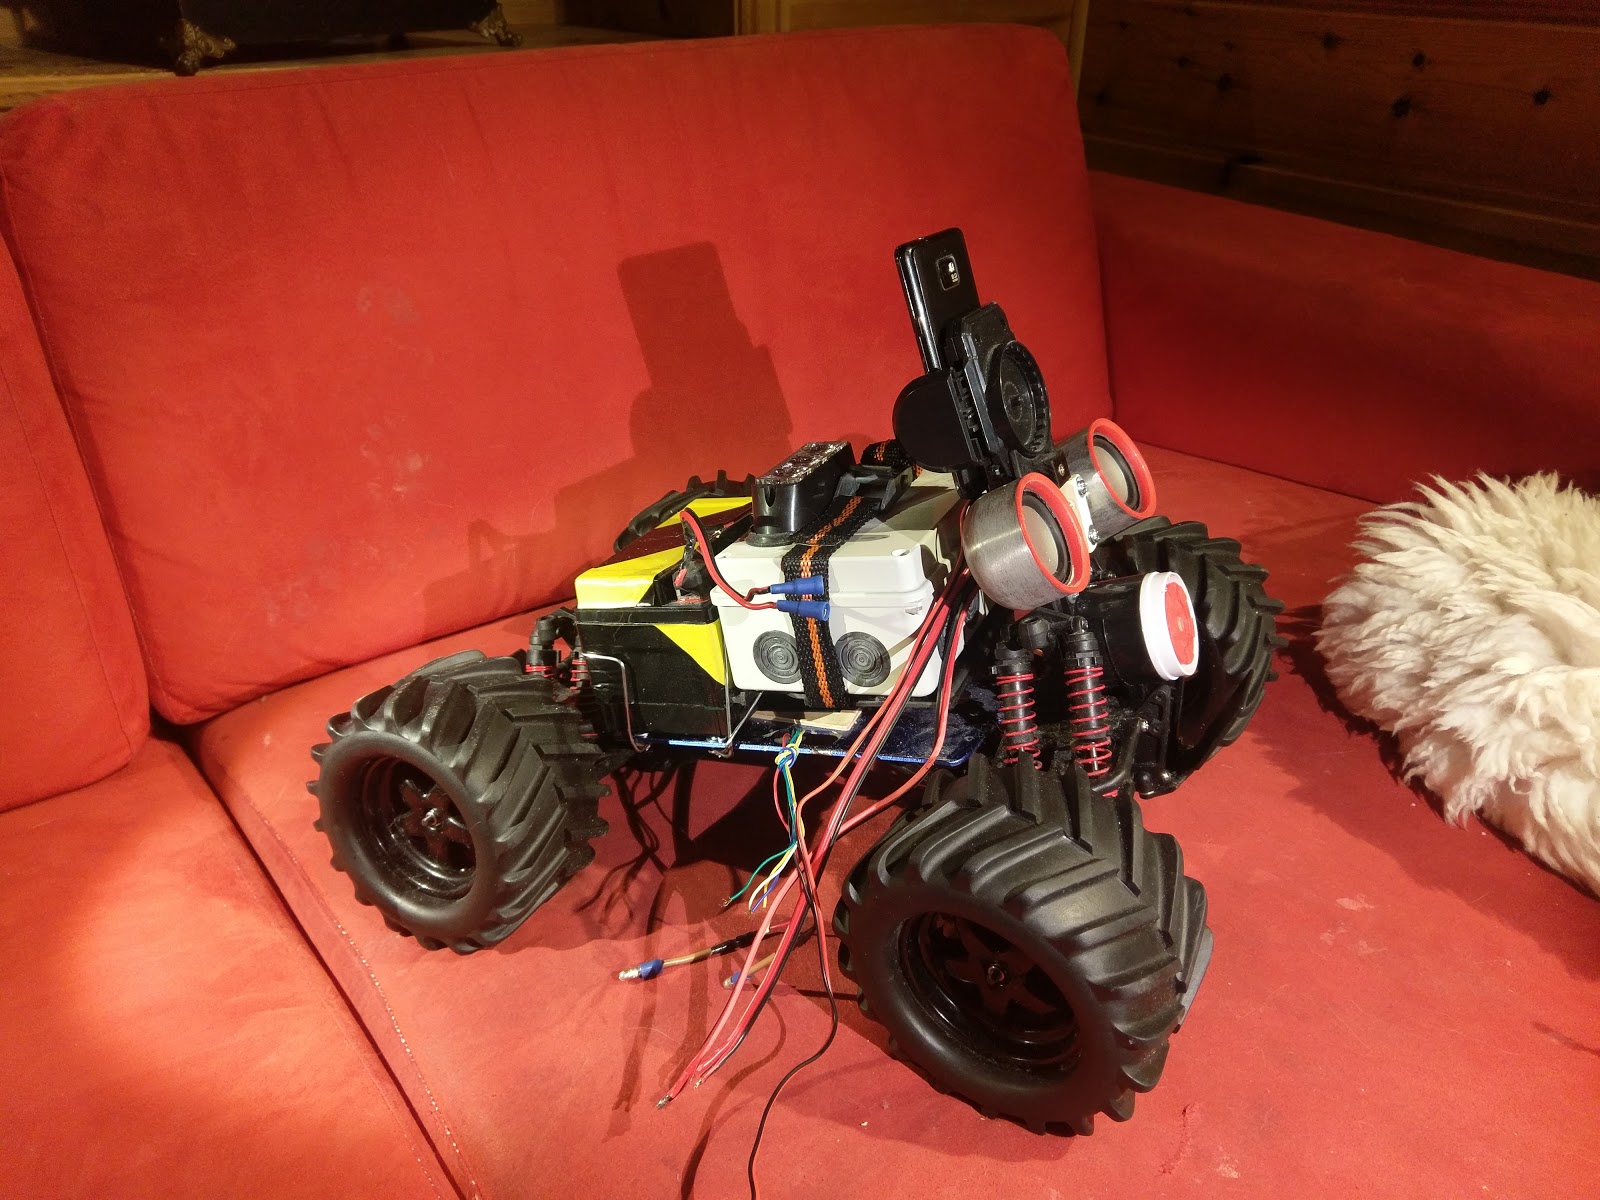
Wheeled rig update
27 December 2016So I put in some time on the wheeled rig : OctoMY™ Wheeled rig with speakers, buzzer, warning light and electronics mounted. Side closeup showing the battery…
-
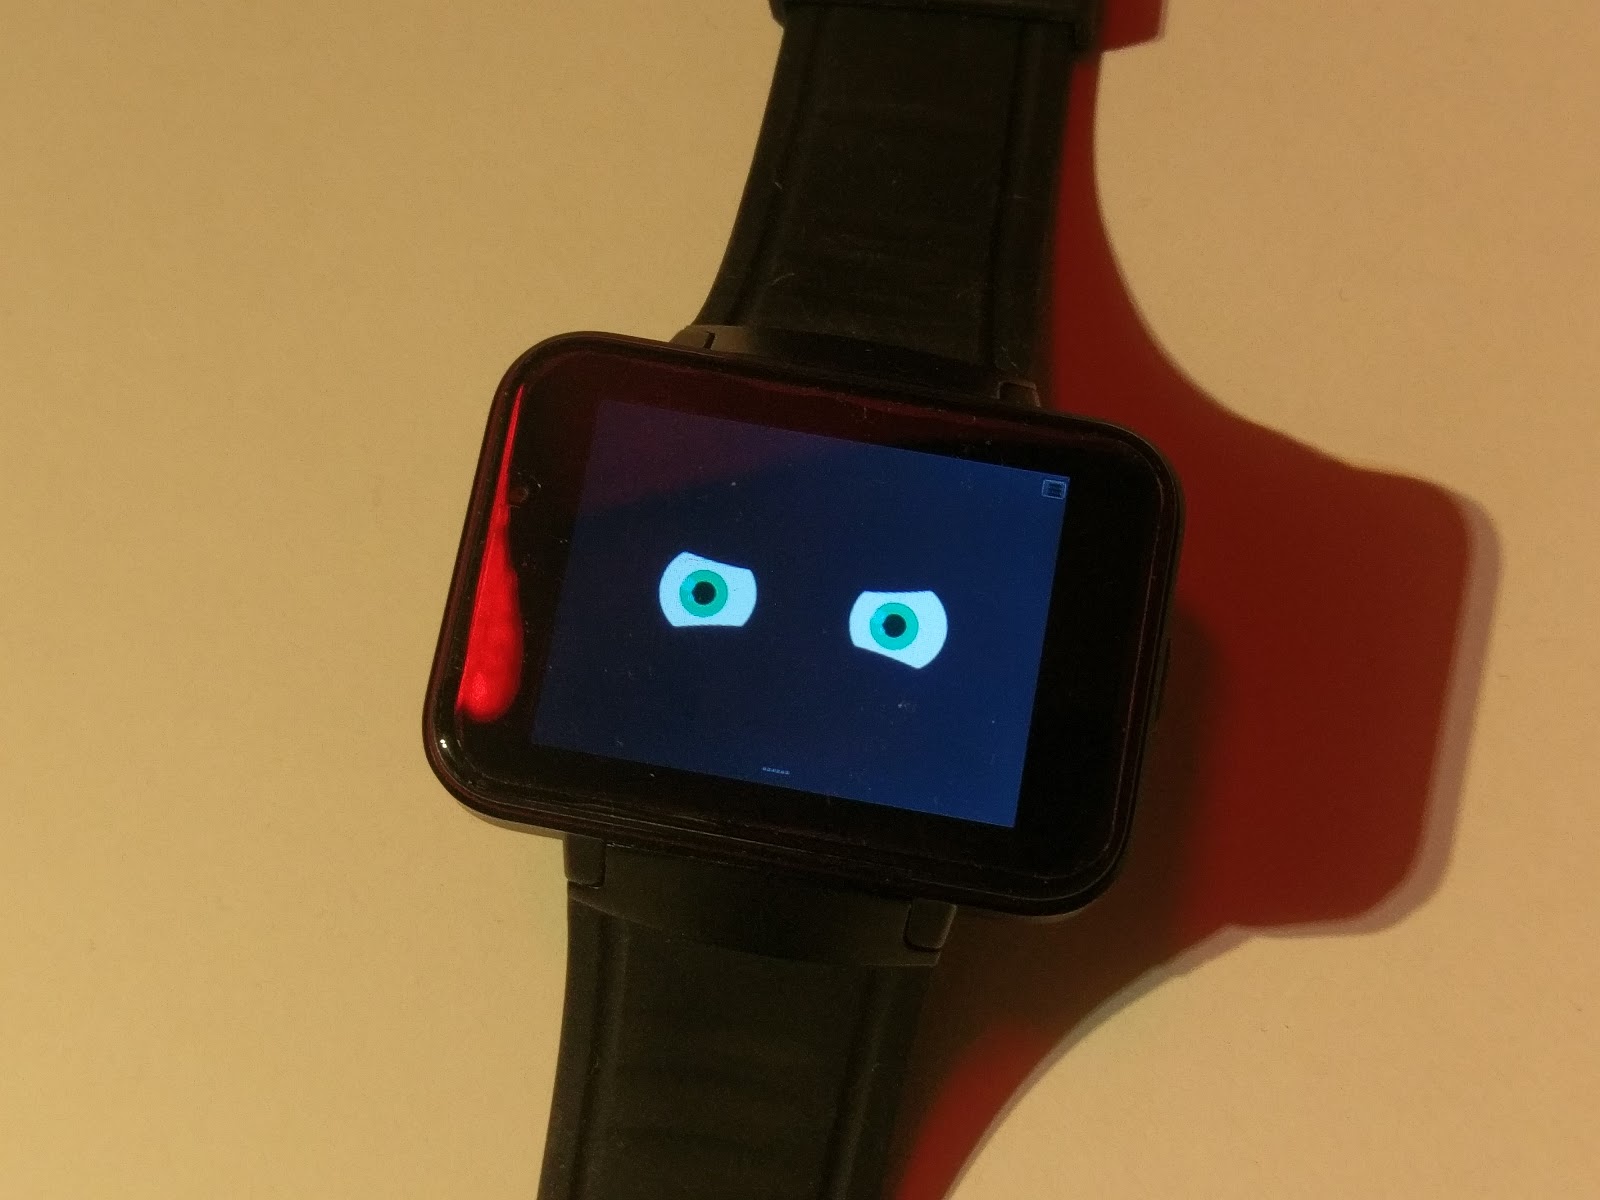
iMacwear W1 First impressions
15 December 2016Good news: I managed to build, deploy and run OctoMY™ Agent without any changes to the source code! It crashed a few times, and I have a bad feeling that these…
-
iMacwear W1 Unboxing
15 December 2016I recently purchased the iMacwear W1 Full Android smart watch for testing with OctoMY™ software. I will put it as a recommended device in the shop page as soon…
-
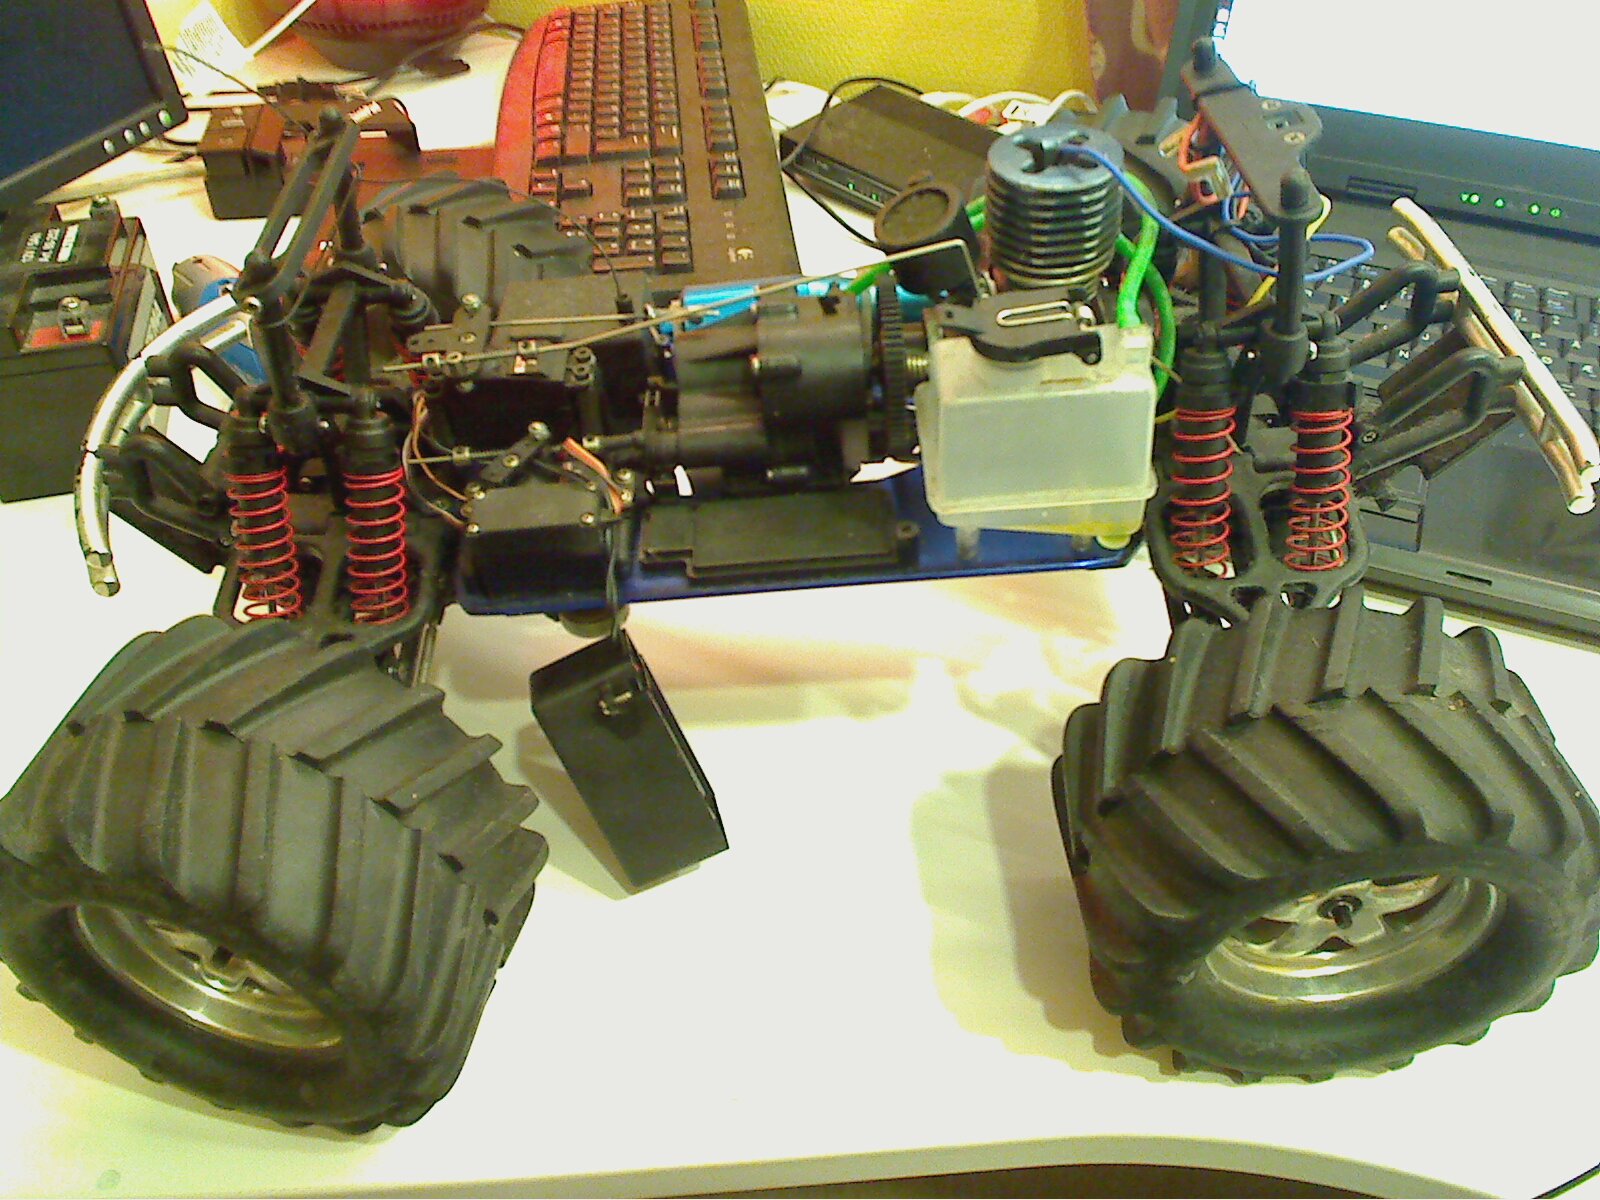
4-Wheeled rig build
18 October 2016I currently have 3 "rigs" I want to integrate OctoMY™ with. The hexy hexapod robot from arcbotics has been featured a few times before on this blog, but the…
-
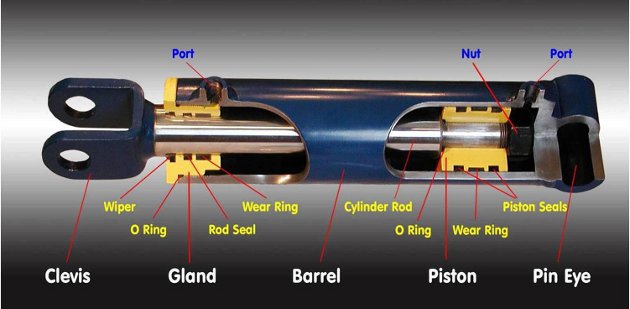
Anatomy of a hydraulic cylinder
10 August 2016Hydraulic cylinders look like this on the inside: The pin eye and clevis is where the cylinder is mounted to the appliance, and are the points between which…
-
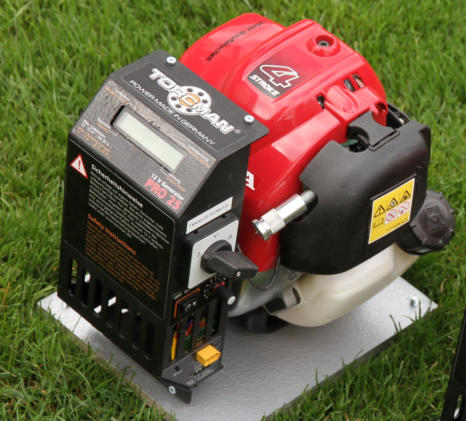
Hybrid BLDC ESC & GX25 ECU
28 December 2015I have advanced my thinking about the power train. More specifically the details for the board that will handle generator stage has converged somewhat. This is…
-
How are lubricants classified & graded?
12 July 2015After reading the manual of the emco F1P CNC Mill and learning that it recommends 4 different lubricants for different parts of the machine I have attained a…
-
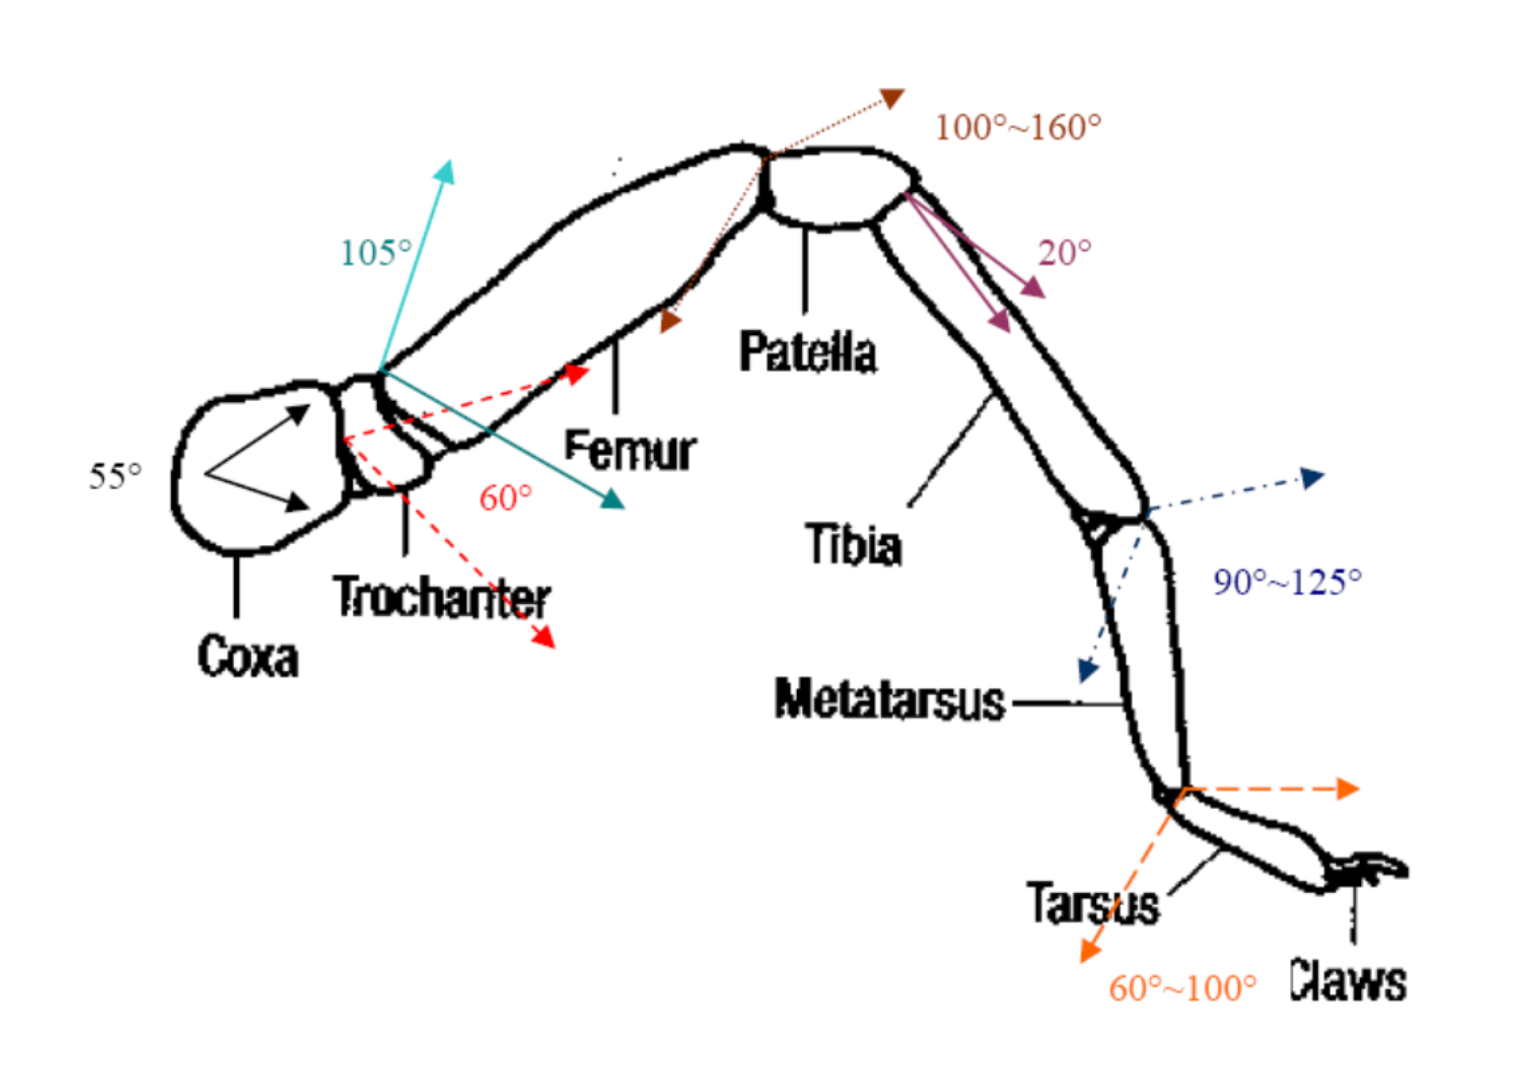
A study of spiders
27 June 2015The decision of copying spiders in the physical design of the robot has spawned some extra focus to the project. Here are some you-tube videos showing spiders…
-
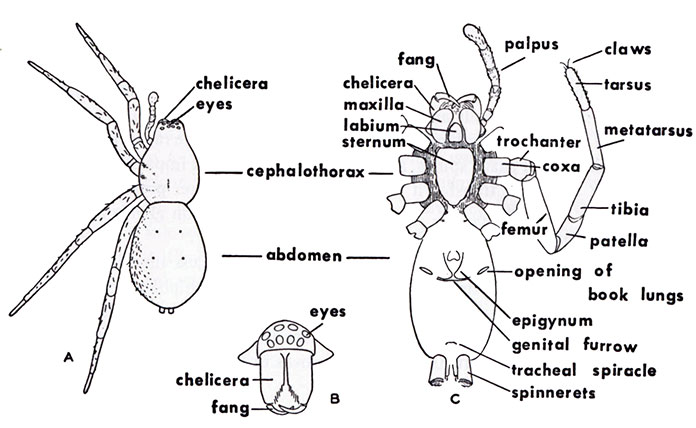
Cobalt blue tarantula
21 June 2015Lately I have pondered (in-between the bouts my extremely demanding and satisfying job) about how to model the physical layout of the robot. I have proclaimed…