Initial development of gait planning in OctoMY™
•
Mr. Developerdude
I started working on an initial MVP gait planning code for OctoMY™. I decided it did not have to perfect, but it needed to exist :P
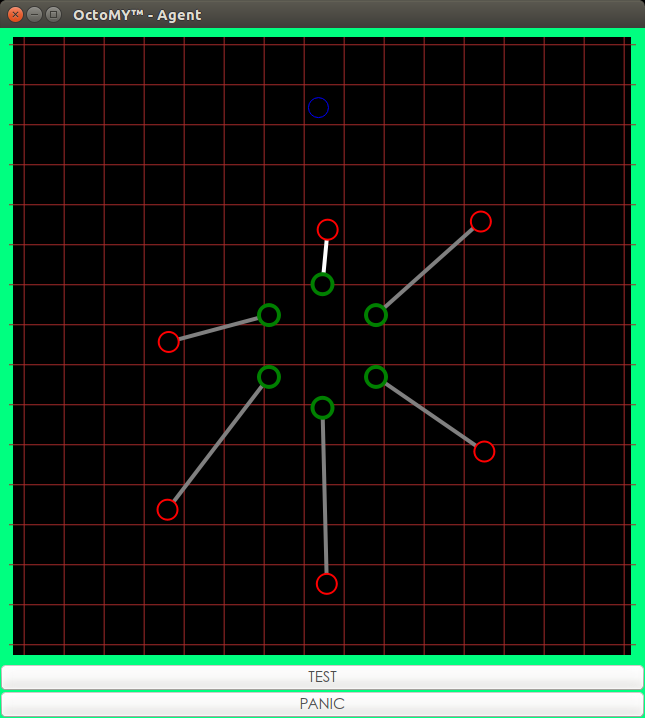
There are a lot of excellent tutorials and working code out there, but I decided to roll my own for a few simple reasons:
- The solutions I found were tied up in existing robot projects and not "stand-alone".
- I found the code to be cumbersome and unstructured, at least from the perspective of a beginner like me.
- I want to learn, tweak and one day outperform the alternatives.