Limb prototype v2.0 hip joint
•
Mr. Developerdude
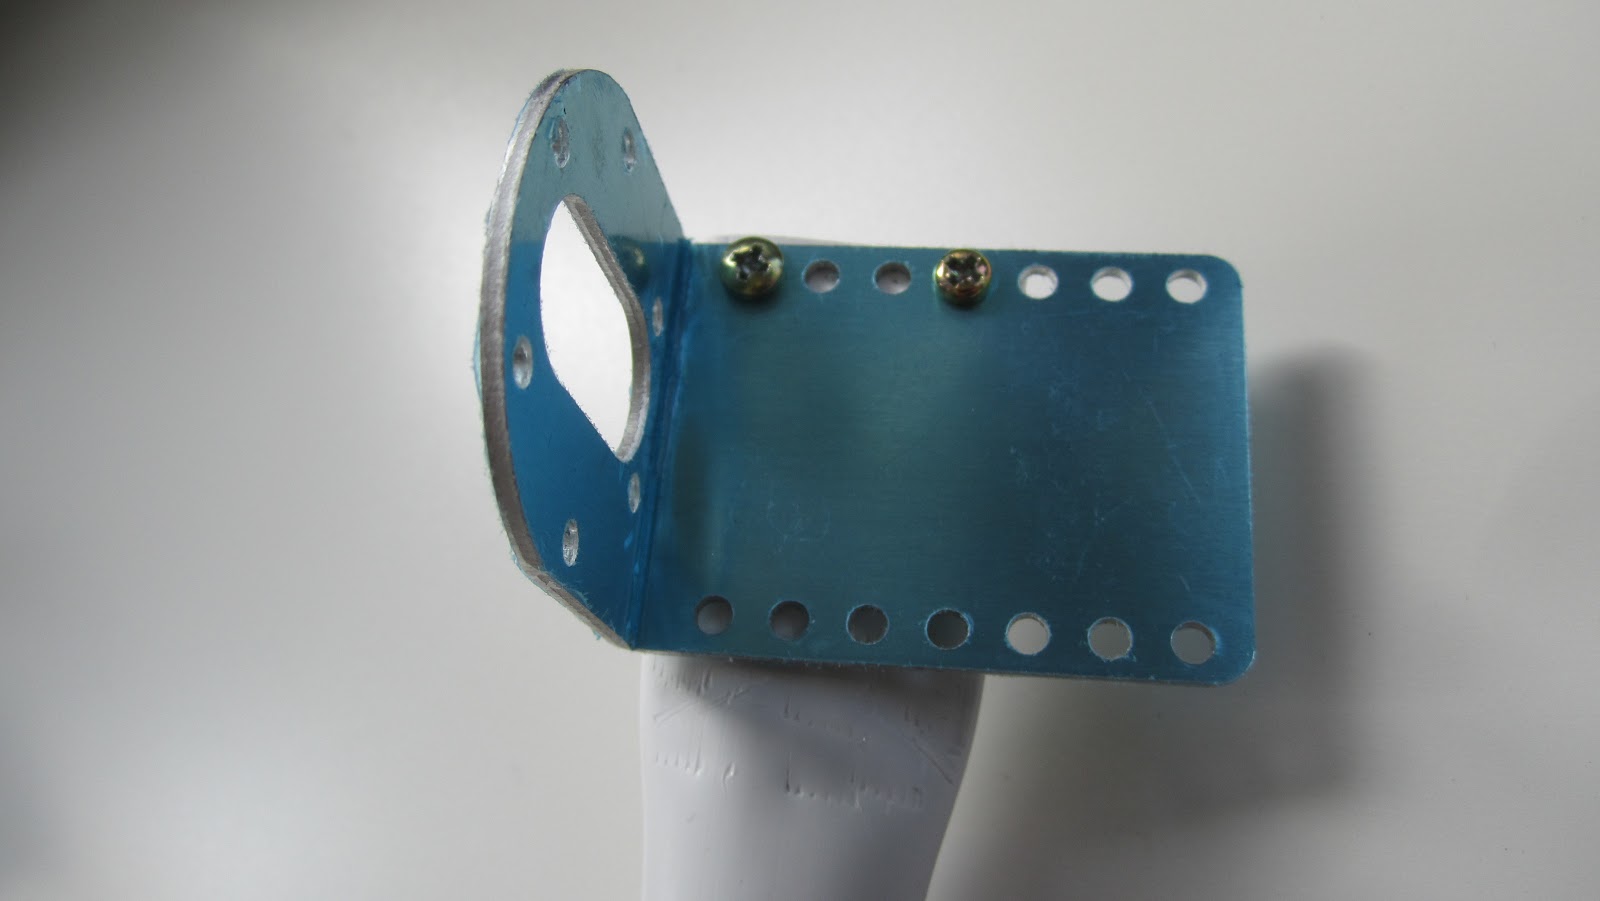
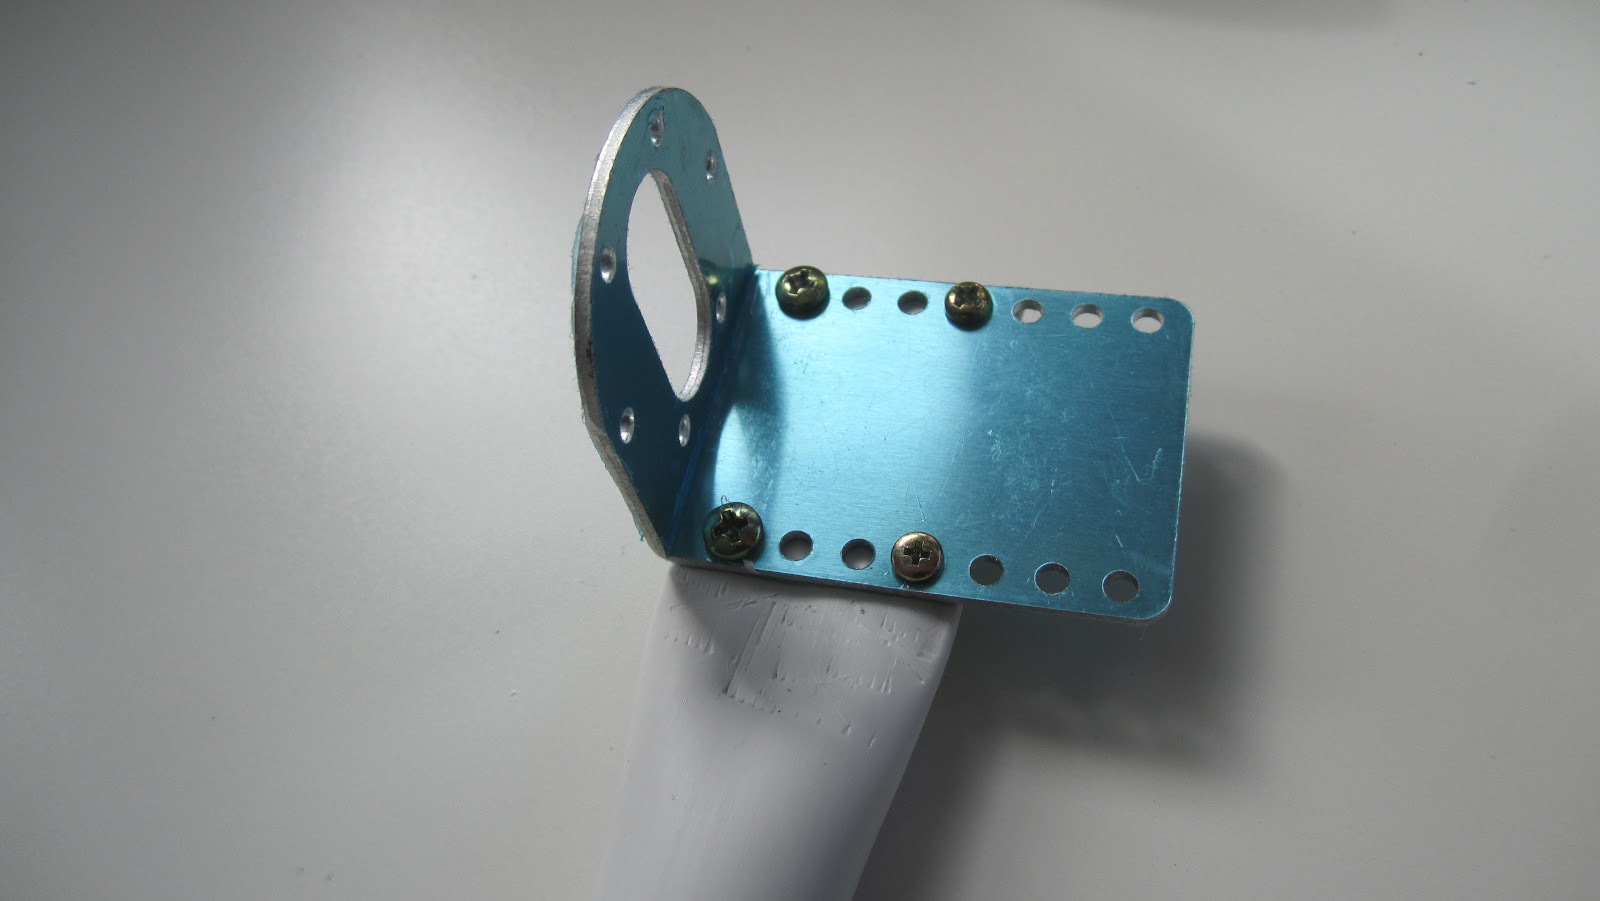
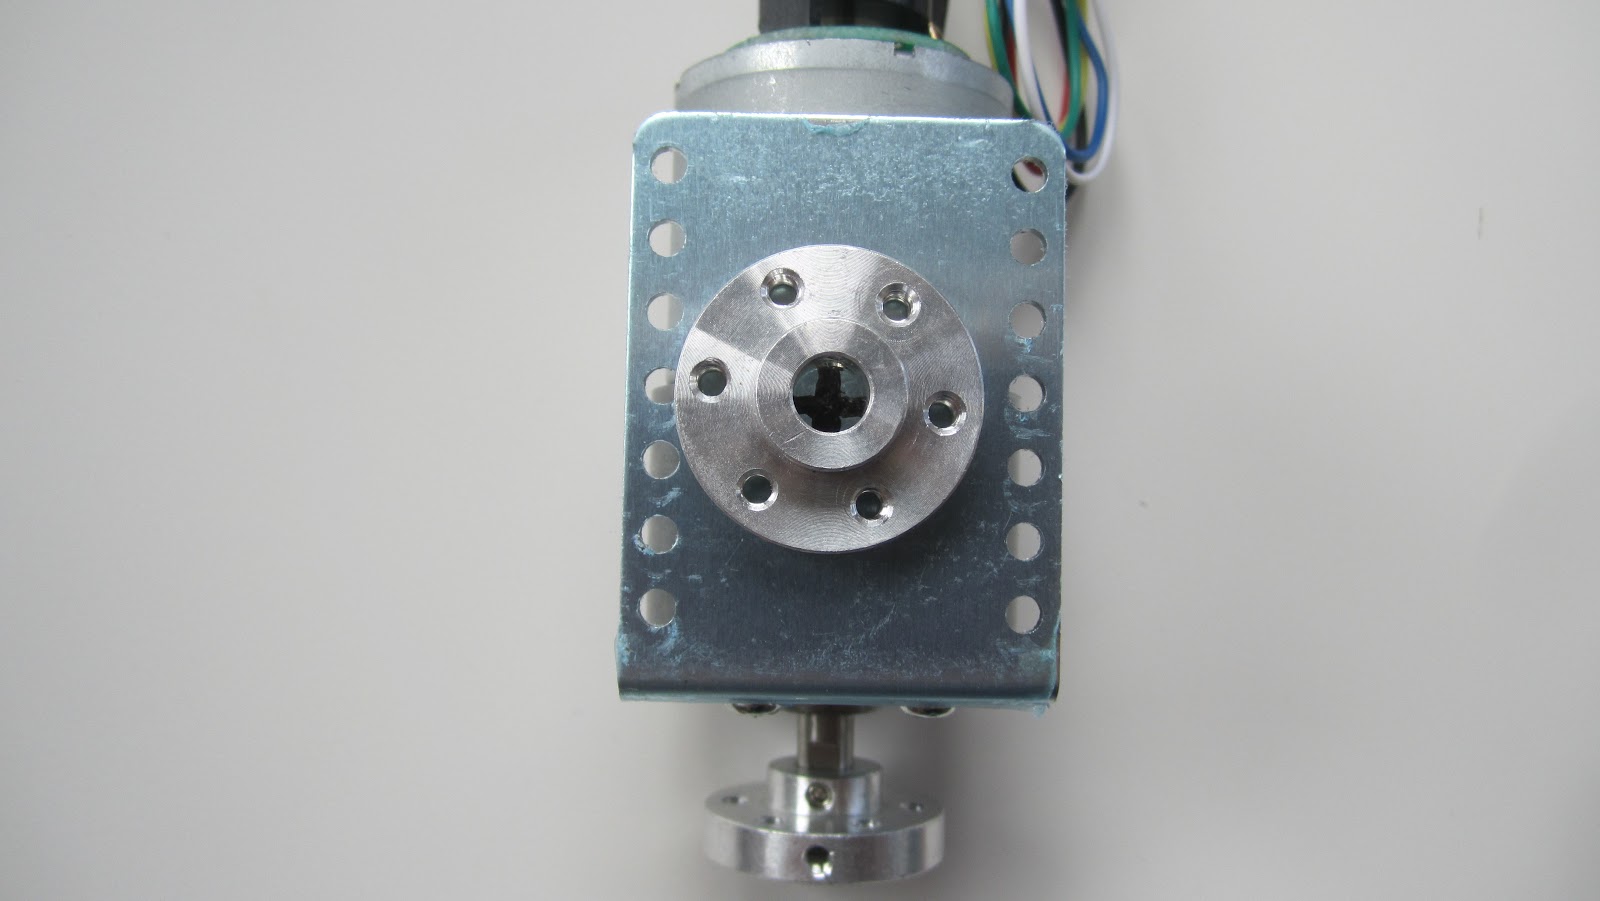
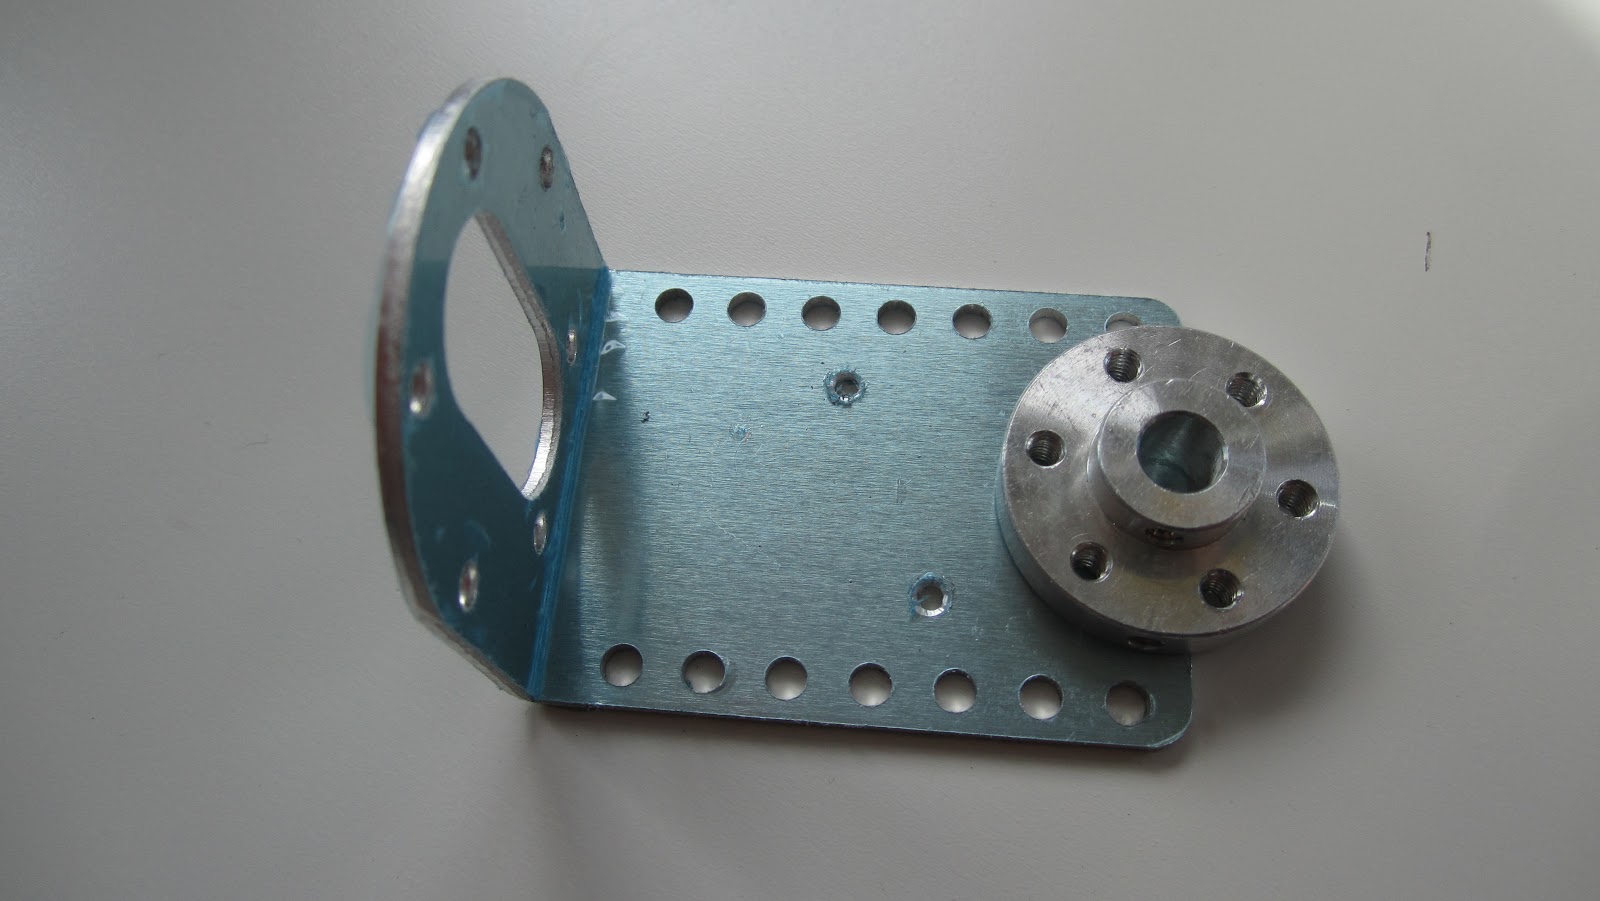
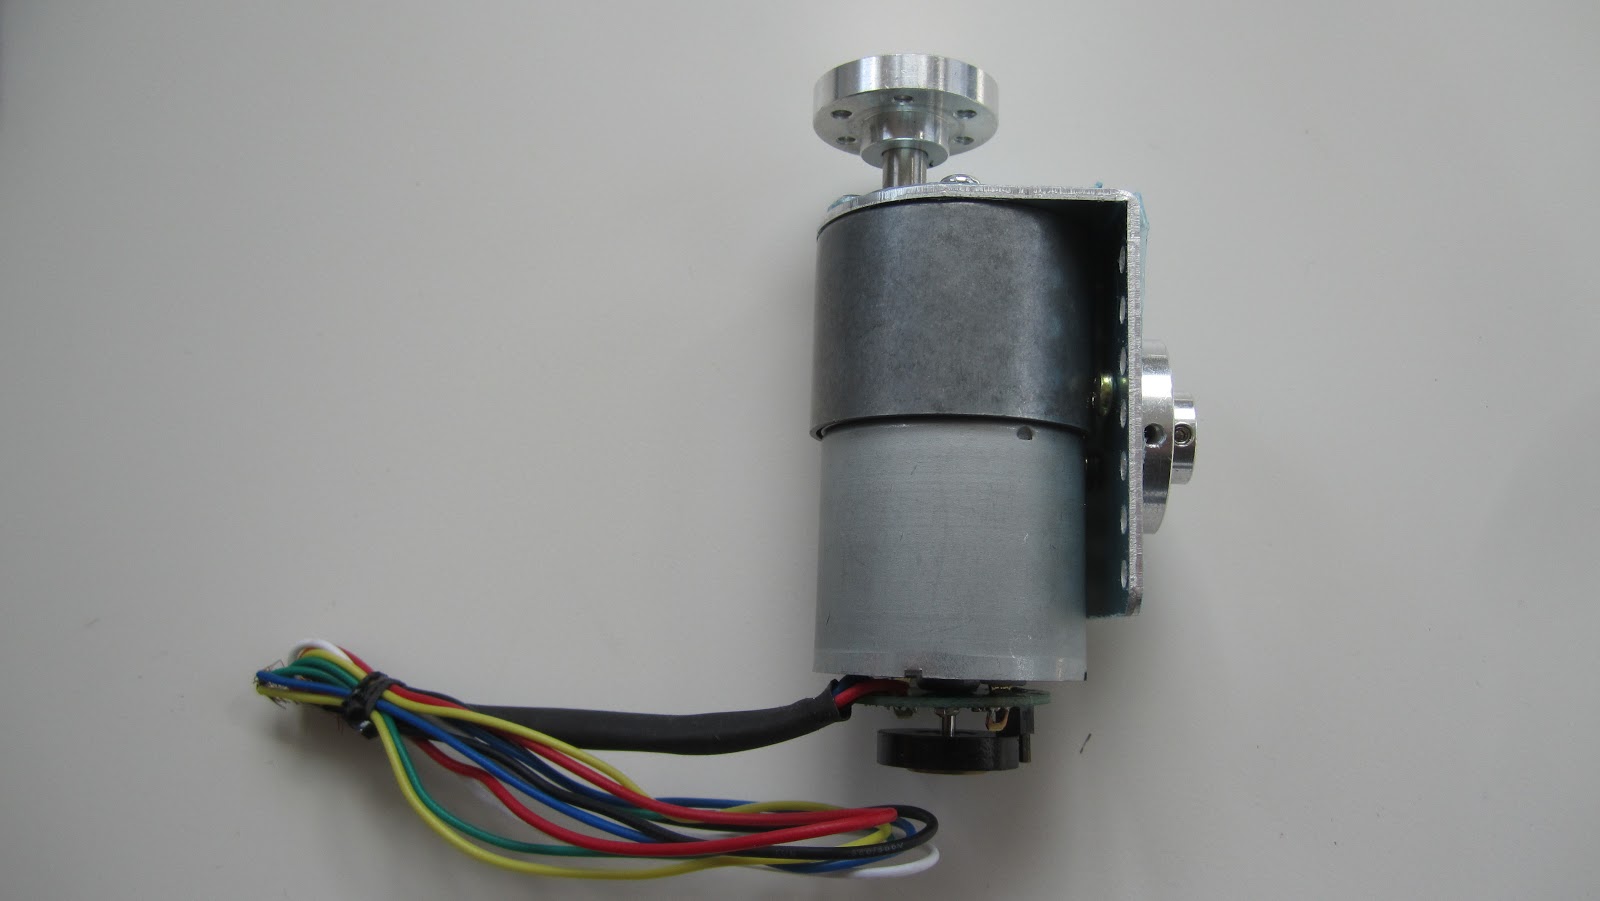
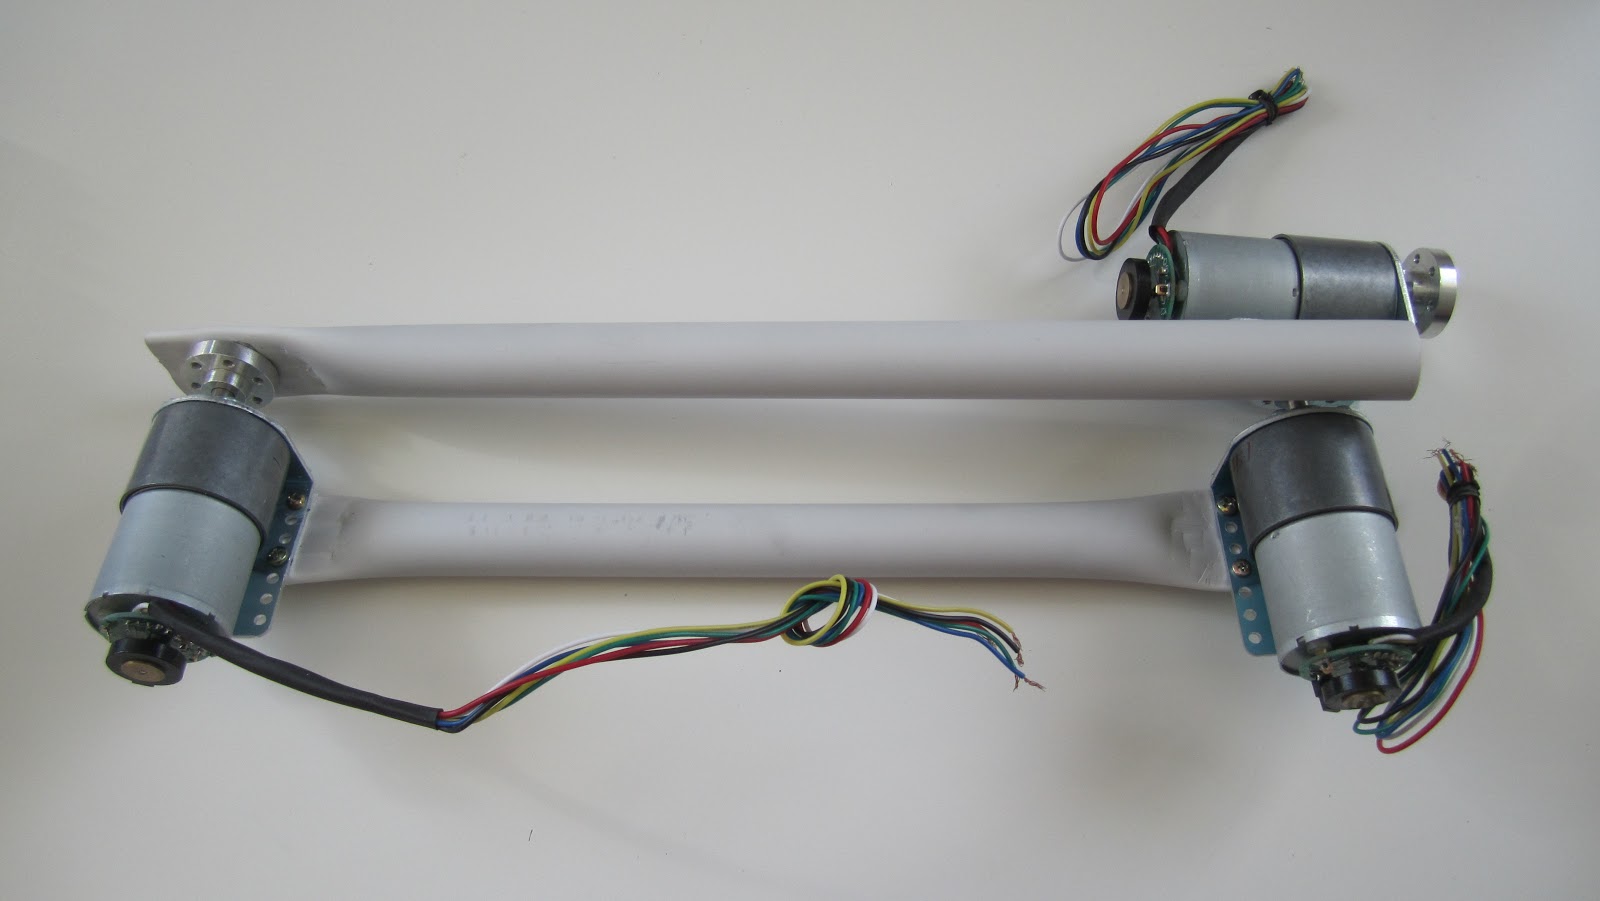
I continued with my limb prototype and added a hip joint. It isn't the most clever design ever but it sort of works as intended. I have learned that joints are hard to get right because:
- The gears in the motors add slack that make the limb "wobble".
- The motor axle needs some kind of reinforcement to be used in a joint. In the prototype I just used the axle and nothing more, but I should look into ways of adding support on the back in addition to the axle, and probably add some bearings to add support.
- The geared motors are very long, and it is hard to conceal them in a normal limb body.